

Robotics
Breaking News
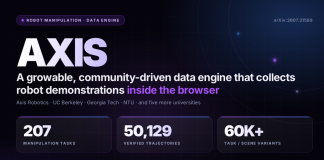
Axis Robotics Releases AXIS: A Browser-Based Data Engine With 207 Robot...
Robot datasets have grown far slower than the models trained on them, mostly because collection stays locked to lab hardware. AXIS moves demonstration collection into a web browser and pushes everything expensive to backend GPUs. The result is 207 tasks and 50,129 verified Franka trajectories, and continual pretraining that lifts π0.5 from 83.9 to 88.8 on LIBERO-Plus while a volume-matched RoboCasa365 control reaches only 57.5.

Meet ‘Code-as-World’: An Agentic Loop That Rewrites Real Videos Into Executable...
Code-as-World recovers editable MuJoCo scene code from real video, then uses those verified worlds to train physical reasoning.
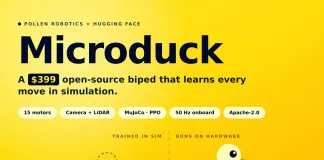
Hugging Face Unveils Microduck: A $399 Open-Source 25 cm Biped You...
Pollen Robotics, the Bordeaux robotics team at Hugging Face, opened pre-orders for Microduck — a 25 cm bipedal robot where every movement is a neural policy trained in MuJoCo and exported to ONNX. At $399, it puts the full sim-to-real loop on a desk: 15 motors, camera, LiDAR, two IMUs, and an Apache-2.0 training stack you can retrain yourself.

Dyna Robotics Introduces Dyna-2: A World-Action Model Pre-Trained on 1 Million...
Dyna Robotics has released Dyna-2, a world-action model pre-trained on more than one million hours of egocentric human video. The technical report establishes three results: a scaling law on human data to 1M hours, the first transfer of that law to unseen robot data, and evidence that video co-training drives cross-embodiment generalization.

Google DeepMind Ships Three Physical AI Models For Whole Body Control,...
Google DeepMind has released Gemini Robotics 2, the intelligence layer for its next generation of robots. The release ships three models: a vision-language-action model for whole body humanoid control, Gemini Robotics ER 2 for embodied reasoning and task orchestration, and an on-device VLA that adapts to new robot bodies in hours. One checkpoint drives Apptronik Apollo 2 and a Franka Duo. Only ER 2 is publicly available.

NVIDIA Releases Cosmos 3 Edge: A 4B-Parameter Open World Model That...
NVIDIA has released Cosmos 3 Edge, a 4-billion-parameter open world model built to run on-device. It helps robots and vision AI agents understand surroundings,...

Mistral AI Releases Robostral Navigate: An 8B Model Enabling Robots to...
Mistral AI introduced Robostral Navigate, an 8B embodied navigation model. It moves robots from a plain-language instruction using only a single RGB camera, with no LiDAR or depth sensors. The model reaches 76.6% success on R2R-CE validation unseen through a pointing method, prefix-caching training, and CISPO online reinforcement learning.
Ant Group’s Robbyant Unveils LingBot-VA 2.0: A Causal Video-Action Model Built...
Ant Group's Robbyant has released the LingBot-VA 2.0 technical report — a Physical AI video-action foundation model built from scratch for embodiment rather than fine-tuned from a video generator. It predicts future states ahead of execution through Foresight Reasoning, re-grounds on every real observation, and reaches 225 Hz asynchronous control. We break down the causal DiT, the sparse-MoE video stream, the semantic visual-action tokenizer, and where the paper's own numbers don't line up.
NVIDIA AI Introduces ASPIRE: A Self-Improving Robotics Framework Reaching 31% Zero-Shot...
NVIDIA's ASPIRE writes and refines robot control programs, then distills validated repairs into a reusable skill library. It gains up to 77 points on LIBERO-Pro and transfers zero-shot to unseen long-horizon tasks.
Meet Qwen-RobotSuite: Three Embodied AI Models for VLA Manipulation, Video World...
We break down Qwen-RobotSuite, the Qwen team's three new embodied AI models. We cover RobotManip, a Vision-Language-Action model built on Qwen3.5-4B for manipulation. We cover RobotWorld, a language-conditioned video world model with a 60-layer MMDiT. We cover RobotNav, a navigation model built on Qwen3-VL across 2B, 4B, and 8B sizes. We walk through the architecture, data pipelines, and benchmark results for each.
NVIDIA Releases Cosmos 3: A Two-Tower Mixture-of-Transformers Foundation Model Unifying Physical...
NVIDIA released Cosmos 3, open omnimodal world models pairing an autoregressive VLM reasoner with a diffusion generator for physical AI.
Genesis AI Releases Nyx, Quadrants, and Genesis World 1.0 Physics Platform...
Genesis AI released Genesis World 1.0 on May 27, 2026 — a four-component simulation platform covering physics, rendering, compilation, and tooling. The system achieves a Pearson correlation of 0.8996 between simulation and real-world robot rollouts, and reduces policy evaluation time from over 200 hours to under 0.5 hours.
Top 10 Physical AI Models Powering Real-World Robots in 2026
Top 10 Physical AI ModelsNVIDIA Isaac GR00T N-Series (N1.5 / N1.6 / N1.7)Google DeepMind Gemini Robotics 1.5Physical Intelligence π0 / π0.5 / π0.7Figure AI...
Google DeepMind Releases Gemini Robotics-ER 1.6: Bringing Enhanced Embodied Reasoning and...
Google DeepMind research team introduced Gemini Robotics-ER 1.6, a significant upgrade to its embodied reasoning model designed to serve as the 'cognitive brain' of...
A Coding Guide to Markerless 3D Human Kinematics with Pose2Sim, RTMPose,...
In this tutorial, we build and run a complete Pose2Sim pipeline on Colab to understand how markerless 3D kinematics works in practice. We begin...
How to Build Advanced Cybersecurity AI Agents with CAI Using Tools,...
In this tutorial, we build and explore the CAI Cybersecurity AI Framework step by step in Colab using an OpenAI-compatible model. We begin by...
Physical Intelligence Team Unveils MEM for Robots: A Multi-Scale Memory System...
Current end-to-end robotic policies, specifically Vision-Language-Action (VLA) models, typically operate on a single observation or a very short history. This 'lack of memory' makes...
NVIDIA Releases DreamDojo: An Open-Source Robot World Model Trained on 44,711...
Building simulators for robots has been a long term challenge. Traditional engines require manual coding of physics and perfect 3D models. NVIDIA is changing...
Meet OAT: The New Action Tokenizer Bringing LLM-Style Scaling and Flexible,...
Robots are entering their GPT-3 era. For years, researchers have tried to train robots using the same autoregressive (AR) models that power large language...
Ant Group Releases LingBot-VLA, A Vision Language Action Foundation Model For...
How do you build a single vision language action model that can control many different dual arm robots in the real world? LingBot-VLA is Ant...
Google DeepMind Introduces SIMA 2, A Gemini Powered Generalist Agent For...
Google DeepMind has released SIMA 2 to test how far generalist embodied agents can go inside complex 3D game worlds. SIMA's (Scalable Instructable Multiworld...

Generalist AI Introduces GEN-θ: A New Class of Embodied Foundation Models...
How do you build a single model that can learn physical skills from chaotic real world robot data without relying on simulation? Generalist AI...

Gemini Robotics 1.5: DeepMind’s ER↔VLA Stack Brings Agentic Robots to the...
Can a single AI stack plan like a researcher, reason over scenes, and transfer motions across different robots—without retraining from scratch? Google DeepMind’s Gemini...
A Coding Guide to End-to-End Robotics Learning with LeRobot: Training, Evaluating,...
In this tutorial, we walk step by step through using Hugging Face’s LeRobot library to train and evaluate a behavior-cloning policy on the PushT...
Physical AI: Bridging Robotics, Material Science, and Artificial Intelligence for Next-Gen...
Table of contentsWhat Do We Mean by “Physical AI”?How Do Materials Contribute to Intelligence?What New Sensing Technologies Are Powering Embodiment?Why Is Neuromorphic Computing Relevant...

Top 12 Robotics AI Blogs/NewsWebsites 2025
Robotics and artificial intelligence are converging at an unprecedented pace, driving breakthroughs in automation, perception, and human-machine collaboration. Staying current with these advancements requires...

NVIDIA AI Team Introduces Jetson Thor: The Ultimate Platform for Physical...
Last week, the NVIDIA robotics team released Jetson Thor that includes Jetson AGX Thor Developer Kit and the Jetson T5000 module, marking a significant...

Meet DeepFleet: Amazon’s New AI Models Suite that can Predict Future...
Amazon has reached a remarkable milestone by deploying its one-millionth robot across global fulfillment and sortation centers, solidifying its position as the world's largest...

NVIDIA AI Introduces End-to-End AI Stack, Cosmos Physical AI Models and...
Nvidia made major waves at SIGGRAPH 2025 by unveiling a suite of new Cosmos world models, robust simulation libraries, and cutting-edge infrastructure—all designed to...

Genie Envisioner: A Unified Video-Generative Platform for Scalable, Instruction-Driven Robotic Manipulation
Embodied AI agents that can perceive, think, and act in the real world mark a key step toward the future of robotics. A central...

NVIDIA AI Presents ThinkAct: Vision-Language-Action Reasoning via Reinforced Visual Latent Planning
Estimated reading time: 5 minutes
Table of contentsIntroductionThe ThinkAct FrameworkExperimental ResultsAblation Studies and Model AnalysisImplementation DetailsConclusion
Introduction
Embodied AI agents are increasingly being called upon to interpret...

URBAN-SIM: Advancing Autonomous Micromobility with Scalable Urban Simulation
Micromobility solutions—such as delivery robots, mobility scooters, and electric wheelchairs—are rapidly transforming short-distance urban travel. Despite their growing popularity as flexible, eco-friendly transport alternatives,...

NVIDIA AI Releases GraspGen: A Diffusion-Based Framework for 6-DOF Grasping in...
Robotic grasping is a cornerstone task for automation and manipulation, critical in domains spanning from industrial picking to service and humanoid robotics. Despite decades...

RoboBrain 2.0: The Next-Generation Vision-Language Model Unifying Embodied AI for Advanced...
Advancements in artificial intelligence are rapidly closing the gap between digital reasoning and real-world interaction. At the forefront of this progress is embodied AI—the...

UC San Diego Researchers Introduced Dex1B: A Billion-Scale Dataset for Dexterous...
Challenges in Dexterous Hand Manipulation Data Collection
Creating large-scale data for dexterous hand manipulation remains a major challenge in robotics. Although hands offer greater flexibility...

Google DeepMind Releases Gemini Robotics On-Device: Local AI Model for Real-Time...
Google DeepMind has unveiled Gemini Robotics On-Device, a compact, local version of its powerful vision-language-action (VLA) model, bringing advanced robotic intelligence directly onto devices....

EmbodiedGen: A Scalable 3D World Generator for Realistic Embodied AI Simulations
The Challenge of Scaling 3D Environments in Embodied AI
Creating realistic and accurately scaled 3D environments is essential for training and evaluating embodied AI. However,...

Meta AI Releases V-JEPA 2: Open-Source Self-Supervised World Models for Understanding,...
Meta AI has introduced V-JEPA 2, a scalable open-source world model designed to learn from video at internet scale and enable robust visual understanding,...

VeBrain: A Unified Multimodal AI Framework for Visual Reasoning and Real-World...
Bridging Perception and Action in Robotics
Multimodal Large Language Models (MLLMs) hold promise for enabling machines, such as robotic arms and legged robots, to perceive...

NVIDIA Releases Cosmos-Reason1: A Suite of AI Models Advancing Physical Common...
AI has advanced in language processing, mathematics, and code generation, but extending these capabilities to physical environments remains challenging. Physical AI seeks to close...

Researchers at Physical Intelligence Introduce π-0.5: A New AI Framework for...
Designing intelligent systems that function reliably in dynamic physical environments remains one of the more difficult frontiers in AI. While significant advances have been...

Sensor-Invariant Tactile Representation for Zero-Shot Transfer Across Vision-Based Tactile Sensors
Tactile sensing is a crucial modality for intelligent systems to perceive and interact with the physical world. The GelSight sensor and its variants have...

This AI Paper Introduces an LLM+FOON Framework: A Graph-Validated Approach for...
Robots are increasingly being developed for home environments, specifically to enable them to perform daily activities like cooking. These tasks involve a combination of...

University of Michigan Researchers Introduce OceanSim: A High-Performance GPU-Accelerated Underwater Simulator...
Marine robotic platforms support various applications, including marine exploration, underwater infrastructure inspection, and ocean environment monitoring. While reliable perception systems enable robots to sense...
NVIDIA AI Releases HOVER: A Breakthrough AI for Versatile Humanoid Control...
The future of robotics has advanced significantly. For many years, there have been expectations of human-like robots that can navigate our environments, perform complex...

Google DeepMind’s Gemini Robotics: Unleashing Embodied AI with Zero-Shot Control and...
Google DeepMind has shattered conventional boundaries in robotics AI with the unveiling of Gemini Robotics, a suite of models built upon the formidable foundation...

Optimizing Imitation Learning: How X‑IL is Shaping the Future of Robotics
Designing imitation learning (IL) policies involves many choices, such as selecting features, architecture, and policy representation. The field is advancing quickly, introducing many new...

π0 Released and Open Sourced: A General-Purpose Robotic Foundation Model that...
Robots are usually unsuitable for altering different tasks and environments. General-purpose models of robots are devised to circumvent this problem. They allow fine-tuning these...

Google DeepMind Researchers Propose RT-Affordance: A Hierarchical Method that Uses Affordances...
In recent years, there has been significant development in the field of large pre-trained models for learning robot policies. The term "policy representation" here...

Researchers from Stanford and Cornell Introduce APRICOT: A Novel AI Approach...
In the rapidly evolving field of household robotics, a significant challenge has emerged in executing personalized organizational tasks, such as arranging groceries in a...

Latent Action Pretraining for General Action models (LAPA): An Unsupervised Method...
Vision-Language-Action Models (VLA) for robotics are trained by combining large language models with vision encoders and then fine-tuning them on various robot datasets; this...

Theia: A Robot Vision Foundation Model that Simultaneously Distills Off-the-Shelf VFMs...
Visual understanding is the abstracting of high-dimensional visual signals like images and videos. Many problems are involved in this process, ranging from depth prediction...

Google DeepMind Researchers Present Mobility VLA: Multimodal Instruction Navigation with Long-Context...
Technological advancements in sensors, AI, and processing power have propelled robot navigation to new heights in the last several decades. To take robotics to...

Hyperion: A Novel, Modular, Distributed, High-Performance Optimization Framework Targeting both Discrete...
In robotics, understanding the position and movement of a sensor suite within its environment is crucial. Traditional methods, called Simultaneous Localization and Mapping (SLAM),...

A Simple Open-loop Model-Free Baseline for Reinforcement Learning Locomotion Tasks without...
The field of deep reinforcement learning (DRL) is expanding the capabilities of robotic control. However, there has been a growing trend of increasing algorithm...

OpenVLA: A 7B-Parameter Open-Source VLA Setting New State-of-the-Art for Robot Manipulation...
A major weakness of current robotic manipulation policies is their inability to generalize beyond their training data. While these policies, trained for specific skills...

Researchers at Stanford Propose TRANSIC: A Human-in-the-Loop Method to Handle the...
Learning in simulation and applying the learned policy to the real world is a potential approach to enable generalist robots, and solve complex decision-making...

This AI Paper Proposes a Pipeline for Improving Imitation Learning Performance...
The practical application of robotic technology in automatic assembly processes holds immense value. However, traditional robotic systems have struggled to adapt to the demands...

Google DeepMind’s SIMA Project Enhances Agent Performance in Dynamic 3D Environments...
The exploration of artificial intelligence within dynamic 3D environments has emerged as a critical area of research, aiming to bridge the gap between static...

From Theory to Robotics: Applying Sums-of-Squares Optimization for Better Control
Reinforcement learning has exhibited notable empirical success in approximating solutions to the Hamilton-Jacobi-Bellman (HJB) equation, consequently generating highly dynamic controllers. However, the inability to...
From Science Fiction to Reality: NVIDIA’s Project GR00T Redefines Human-Robot Interaction
NVIDIA's unveiling of Project GR00T, a unique foundation model for humanoid robots, and its commitment to the Isaac Robotics Platform and the Robot Operating...

GeFF: Revolutionizing Robot Perception and Action with Scene-Level Generalizable Neural Feature...
When a whirring sound catches your attention, you're walking down the bustling city street, carefully cradling your morning coffee. Suddenly, a knee-high delivery robot...

This AI Research from Google DeepMind Unlocks New Potentials in Robotics:...
In robotics, natural language is an accessible interface for guiding robots, potentially empowering individuals with limited training to direct behaviors, express preferences, and offer...

Google Deepmind and University of Toronto Researchers’ Breakthrough in Human-Robot Interaction:...
Numerous challenges underlying human-robot interaction exist. One such challenge is enabling robots to display human-like expressive behaviors. Traditional rule-based methods need more scalability in...

Researchers from Stanford Present Mobile ALOHA: A Low-Cost and Whole-Body Teleoperation...
Since it enables humans to teach robots any skill, imitation learning via human-provided demonstrations is a promising approach for creating generalist robots. Lane-following in...

This Paper Explores Efficient Predictive Control with Sparsified Deep Neural Networks
Robotics is currently exploring how to enhance complex control tasks, such as manipulating objects or handling deformable materials. This research niche is crucial as...

How do You Unveil the Power of GPT-4V in Robotic Vision-Language...
The problem of achieving superior performance in robotic task planning has been addressed by researchers from Tsinghua University, Shanghai Artificial Intelligence Laboratory, and Shanghai...

Researchers from NYU and Meta Introduce Dobb-E: An Open-Source and General...
The team of researchers from NYU and Meta aimed to address the challenge of robotic manipulation learning in domestic environments by introducing DobbE, a...

KAIST Researchers Introduce Quatro++: A Robust Global Registration Framework Exploiting Ground...
The problem of sparsity and degeneracy issues in LiDAR SLAM has been addressed by introducing Quatro++, a robust global registration framework developed by researchers...

This AI Research from MIT and Meta AI Unveils an Innovative...
Researchers from MIT and Meta AI have developed an object reorientation controller that can utilize a single depth camera to reorient diverse shapes of...

Meet GO To Any Thing (GOAT): A Universal Navigation System that...
A team of researchers from the University of Illinois Urbana-Champaign, Carnegie Mellon University, Georgia Institute of Technology, University of California Berkeley, Meta AI Research,...

This AI Paper from MIT Introduces a Novel Approach to Robotic...
A team of researchers from MIT and the Institute of AI and Fundamental Interactions (IAIFI) has introduced a groundbreaking framework for robotic manipulation, addressing...

Duke University Researchers Propose Policy Stitching: A Novel AI Framework that...
In robotics, researchers face challenges in using reinforcement learning (RL) to teach robots new skills, as these skills can be sensitive to changes in...

Researchers from NVIDIA and UT Austin Introduced MimicGen: An Autonomous Data...
Training robots to perform various manipulation behaviors has been made possible by imitation learning from human demonstrations. One popular method involves having human operators...

Researchers at Stanford Introduce RoboFuME: Revolutionizing Robotic Learning with Minimal Human...
In many domains that involve machine learning, a widely successful paradigm for learning task-specific models is to first pre-train a general-purpose model from an...

Meet HITL-TAMP: A New AI Approach to Teach Robots Complex Manipulation...
Teaching robots complicated manipulation skills through observation of human demonstrations has shown promising results. Providing extensive manipulation demonstrations is time-consuming and labor costly, making...

Meet GROOT: A Robust Imitation Learning Framework for Vision-Based Manipulation with...
With the increase in the popularity and use cases of Artificial Intelligence, Imitation learning (IL) has shown to be a successful technique for teaching...

This AI Paper Proposes a NeRF-based Mapping Method that Enables Higher-Quality...
In this paper, researchers have introduced a NeRF-based mapping method called H2-Mapping, aimed at addressing the need for high-quality, dense maps in real-time applications,...

Meet the Air-Guardian: An Artificial Intelligence System Developed by MIT Researchers...
In a world where autonomous systems are becoming increasingly prevalent, ensuring their safety and performance is paramount. Autonomous aircraft, in particular, have the potential...
Google DeepMind Releases Open X-Embodiment that Includes a Robotics Dataset with...
The latest advancements in the fields of Artificial Intelligence and Machine Learning have demonstrated the ability of large-scale learning from varied and vast datasets...
Meet ConceptGraphs: An Open-Vocabulary Graph-Structured Representation for 3D Scenes
Capturing and encoding information about a visual scene, typically in the context of computer vision, artificial intelligence, or graphics, is called Scene representation. It...

Shanghai Jiao Tong University Researchers Unveil RH20T: The Ultimate Robotic Dataset...
Robotic manipulation is advancing towards the goal of enabling robots to swiftly acquire new skills through one-shot imitation learning and foundational models. While the...

Researchers from UT Austin Introduce MUTEX: A Leap Towards Multimodal Robot...
Researchers have introduced a cutting-edge framework called MUTEX, short for "MUltimodal Task specification for robot EXecution," aimed at significantly advancing the capabilities of robots...
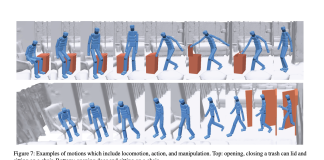
Researchers from Seoul National University Introduces Locomotion-Action-Manipulation (LAMA): A Breakthrough AI...
Researchers from Seoul National University address a fundamental challenge in robotics - the efficient and adaptable control of robots in dynamic environments. Traditional robotics...

Can Low-Cost Quadrupedal Robots Master Parkour? Unveiling a Revolutionary Learning System...
The quest to make robots perform complex physical tasks, such as navigating challenging environments, has been a long-standing challenge in robotics. One of the...

Meet PhysObjects: An Object-Centric Dataset of 36.9K Crowd-Sourced and 417K Automated...
In the real world, information is often conveyed through a combination of text images or videos. To understand and interact with this information effectively,...

How Can Robots Make Better Decisions? MIT and Stanford Researchers Introduce...
The capacity to choose continuous values, such as grasps and object placements, that satisfy complicated geometric and physical constraints, like stability and lack of...

MIT Researchers Developed an Artificial Intelligence (AI) Technique that Enables a...
Whole-body manipulation is a strength of humans but a weakness of robots. The robot interprets each possible contact point between the box and the...

Watch and Learn Little Robot: This AI Approach Teaches Robots Generalizable...
Robots have always been at the center of attention in the tech landscape. They always found a place in sci-fi movies, kid shows, books,...

Meer Pyrus Base: A New Open-Source Python-Based Platform for the Two-Dimensional...
Robotics, the branch which is completely dedicated to the field of Electronics and Computer Science Engineering is now being connected to Artificial Intelligence for...

MIT and Harvard Researchers Propose (FAn): A Comprehensive AI System that...
In a new AI research, a team of MIT and Harvard University researchers has introduced a groundbreaking framework called "Follow Anything" (FAn). The system...

CMU Researchers Developed a Simple Distance Learning AI Method to Transfer...
A significant barrier to progress in robot learning is the dearth of sufficient, large-scale data sets. Data sets in robotics have issues with being...

Google DeepMind Researchers Introduce RT-2: A Novel Vision-Language-Action (VLA) Model that...
Large language models can enable fluent text generation, emergent problem-solving, and creative generation of prose and code. In contrast, vision-language models enable open-vocabulary visual...

Meet RoboPianist: A New Benchmarking Suite for High-Dimensional Control in Piano...
The gauging process in the domains of control and reinforcement learning advance is quite challenging. A particularly underserved area has been robust benchmarks that...

Researchers from MIT and UC Berkeley introduced a framework that enables humans to...
In collaboration with New York University and the University of California at Berkeley, researchers from MIT have devised a groundbreaking framework that empowers humans...

Researchers from Columbia University and Deepmind Introduce GPAT: A Transformer-Based Model...
Autonomous robotic systems capable of assembling new objects through visuospatial reasoning hold great potential for a broad range of real-world applications. Despite remarkable advancements...

Check Out KNOWNO (Know When You Don’t Know): A Framework that...
Large Language Models (LLMs) are known for their human-like capabilities to generate content, answer questions, and that too with linguistic accuracy and consistency. These...

Amazon Robotics Open-Sources ARMBench: A Large Open-Source Dataset For Training Robots
Picking, sorting, and packaging are just some of the many warehouse operations that may be automated using robotic object-handling systems. It is not easy...

Unified Understanding: This AI Approach Provides a Better 3D Mapping for...
Developing robots that could do daily tasks for us is a long-lasting dream of humanity. We want them to walk around and help us...

A New AI Research Introduces CACTI: A Framework For Multi-Task Multi-Scene...
Recent advances in learning-based control have brought us closer to the objective of building an embodied agent with generalizable human-like abilities. Natural language processing...